Runtime is building a simulation-based robot policy. No fine-tuning or teleoperation.
ExploreBlog.
-
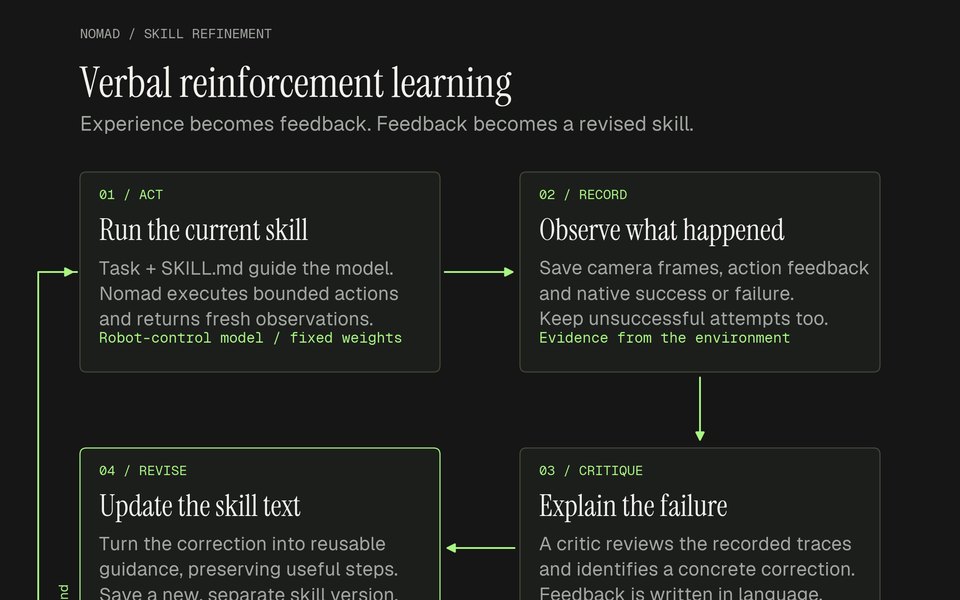 Benchmarking Verbal Reinforcement Learning for Robotics
Can text-based skills improve robotic manipulation? Experiments with Nomad, LIBERO and frontier models.
Read the post
-
 Introducing SimInfinity
The world’s largest open-source robotic simulation benchmark. Coming soon: 10K open-source simulations with well-defined robotic tasks inspired by real-world activities across factories, logistics, homes, and beyond.
View on X
-
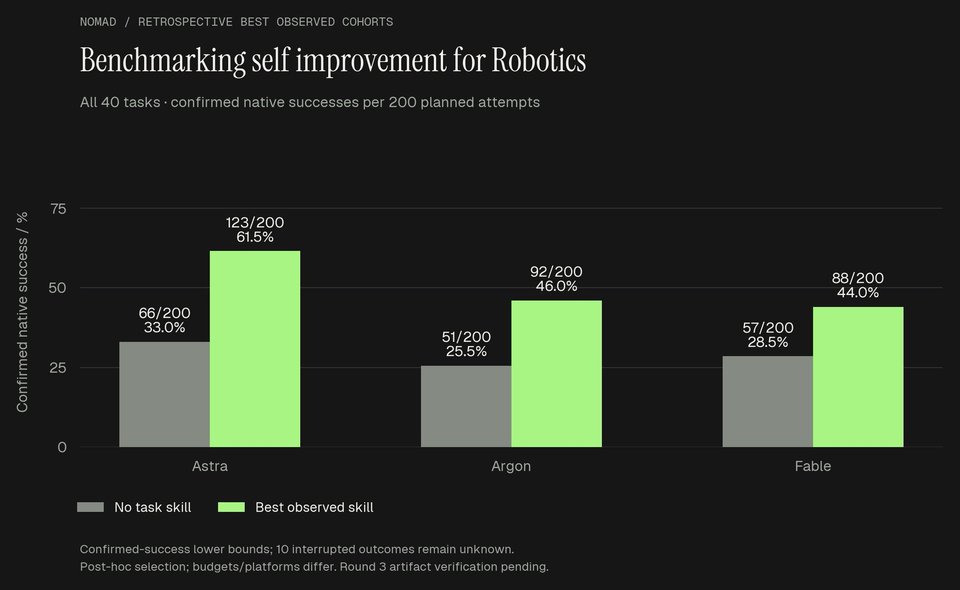 Verbal reinforcement learning is very effective for improving agentic performance on benchmarks, but we wanted to test how this transfers to robotics. We ran GPT 6 Astra, Gemini Argon 4, and Fable 5.1 on the LIBERO benchmark, and then iteratively developed skills which…
View on X
-
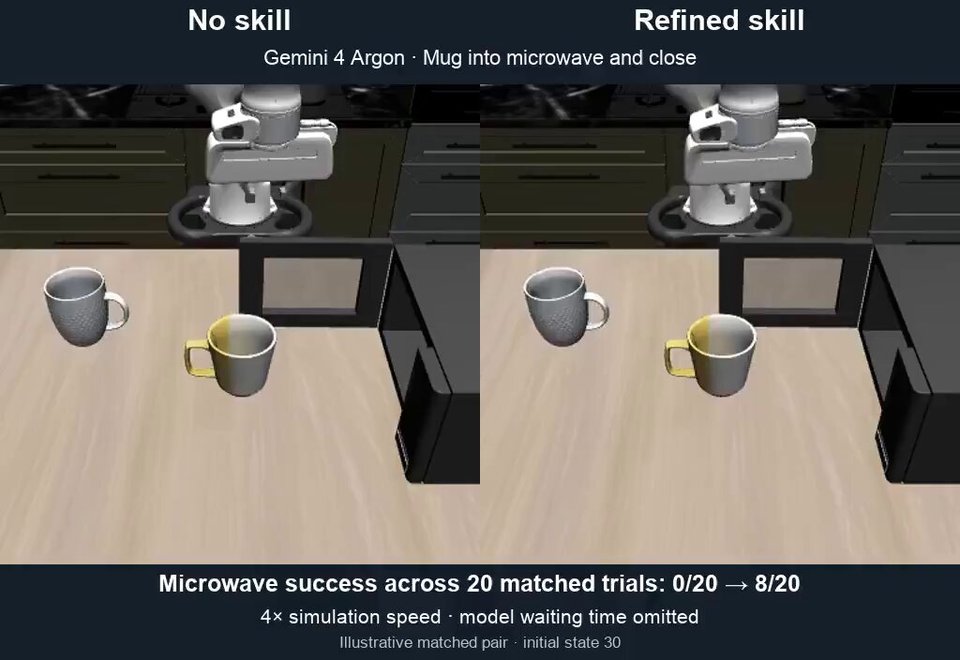 Frontier models like GPT-6 Astra and Gemini Argon 4 can control robots, but how much does the harness around them impact performance? We used our Nomad-Harness to test Gemini Argon on LIBERO tasks to test if text based skills could help with harder tasks that require more…
View on X
-
 Runtime (YC F26): The simulation and evaluation platform for physical AI. Build realistic environments, stress-test robot policies across thousands of variations, and identify failures before real-world deployment. Building robots? We’d love to chat!
View on X
run·time (n.) The moment a program stops being a plan and starts to act.